Research
Vision
My Fusion Intelligence Laboratory (FIL) aims to use machine intelligence and multi-source information fusion to benefit humanity. The idea of Fusion Intelligence was first conceived during my time at Imperial College London and was formalised in 2024 when I established FIL at the University of Exeter.
Research areas
Under the vision of Fusion Intelligence, my research spans five closely connected directions:
- Multimodal Learning and Image Fusion
- Robotics and Embodied Intelligence
- Human-Centered Computer Vision
- Trustworthy and Responsible AI
- AI for Healthcare
Multimodal learning and image fusion provide the methodological foundation for integrating complementary visual and sensory information. Robotics and embodied intelligence develop research capacity for studying intelligent systems in physical environments. Human-centered computer vision focuses on understanding and assisting people in real-world scenarios. Trustworthy and responsible AI focuses on robustness, privacy protection, and socially responsible AI technologies. AI for healthcare explores how multimodal learning and image analysis can support the analysis of medical images and biomedical multimodal data.
Research topics
1. Multimodal Learning and Image Fusion
Multimodal learning and image fusion form the methodological foundation of my research on Fusion Intelligence. This direction focuses on developing learning-based methods that can integrate complementary information from multiple modalities and data sources to produce more informative and robust representations.
Beyond developing individual algorithms, I have also contributed to the community through surveys, benchmarks, comparative studies, open resources, and books, including the published book Image Fusion and the open-source book project Intelligence of Fusion. These efforts aim to organise and communicate the foundations, progress, and future directions of multimodal information fusion. Together, they provide the core perception and representation-learning capabilities that support my broader research in embodied intelligence, trustworthy AI, and healthcare applications.
Selected publications:
- X. Zhang, Y. Demiris. Visible and Infrared Image Fusion using Deep Learning, IEEE Transactions on Pattern Analysis and Machine Intelligence, vol. 45, no. 8, pp. 10535-10554, 2023. (ESI Highly Cited Paper, ESI hot paper)
- X. Zhang. Deep Learning-based Multi-focus Image Fusion: A Survey and A Comparative Study, IEEE Transactions on Pattern Analysis and Machine Intelligence, vol. 44, No. 9, pp. 4819 – 4838, 2022. [Link] (ESI Highly Cited Paper)
- X. Zhang. Benchmarking and Comparing Multi-exposure Image Fusion Algorithms. Information Fusion, vol. 74, pp. 111-131, 2021. (The first multi-exposure image fusion benchmark) [Benchmark link]
- X. Zhang, P. Ye, G. Xiao. VIFB: A Visible and Infrared Image Fusion Benchmark, In the Proceedings of IEEE/CVF Conference on Computer Vision Workshops, 2020. (The first image fusion benchmark, which has been utilized by researchers from more than 10 countries.) [Benchmark link]
- Z. Zhao, A. Howes, X. Zhang*. MultiTaskVIF: Segmentation-oriented visible and infrared image fusion via multi-task learning, IEEE Transactions on Image Processing, 2026. [Link]
- Z. Zhao, X. Zhang*. SSVIF: Self-Supervised Segmentation-Oriented Visible and Infrared Image Fusion. IEEE Transactions on Image Processing, 2026. [Link]
- G. Xiao, D.P. Bavirisetti , G. Liu , X. Zhang, Image Fusion, Springer Nature Singapore and Shanghai Jiao Tong University Press, 2020. This book has won the National Science and Technology Academic Publications Fund of China (2019).
- X. Zhang. Intelligence of Fusion: Deep Learning-based Image Fusion (written in Chinese). 2025. This book is available here.
* Corresponding authors
2. Robotics and Embodied Intelligence
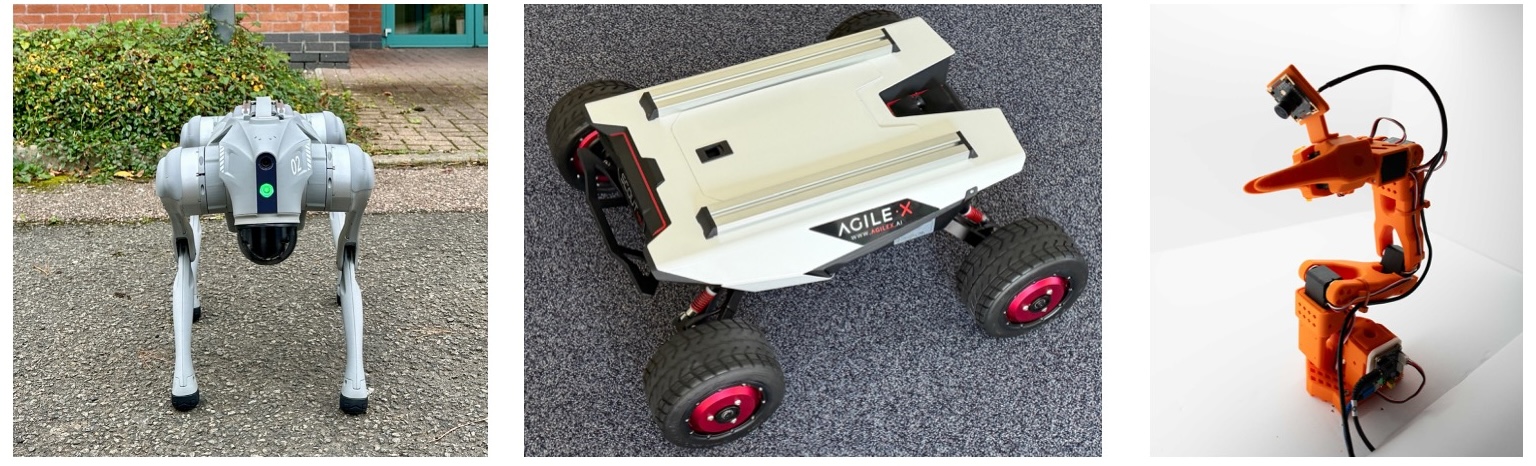
My lab has received funding and support from the Royal Society, the European Commission, NVIDIA Academic Grant, and UKRI AIRR to develop research capacity in robotics and embodied intelligence.
We are building a robotics research platform with mobile robots, different sensors, and NVIDIA Jetson edge-computing devices.
Related publications:
- Q. Liu, N. Wang, Z. Zhao, X. Zhang*. ActiveReID: Target-Conditioned Active Viewpoint Optimization for Mobile Robot Person Re-Identification. IEEE Robotics and Automation Letters, 2026.
3. Human-Centered Computer Vision
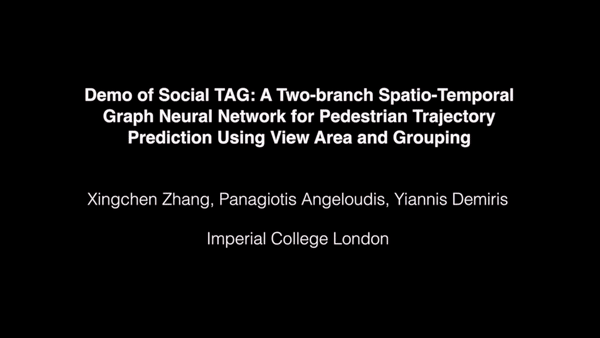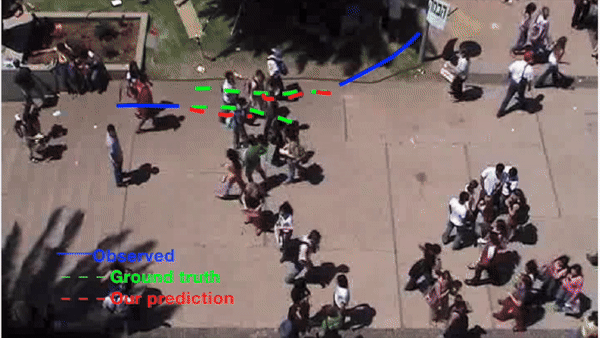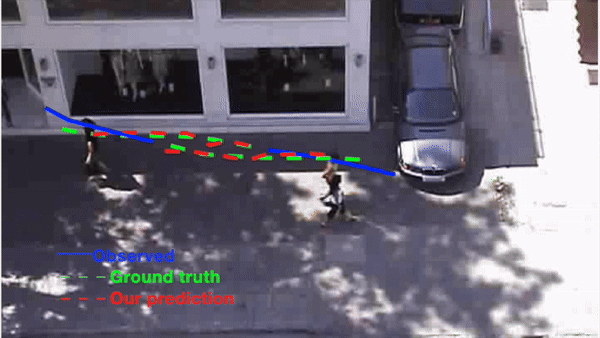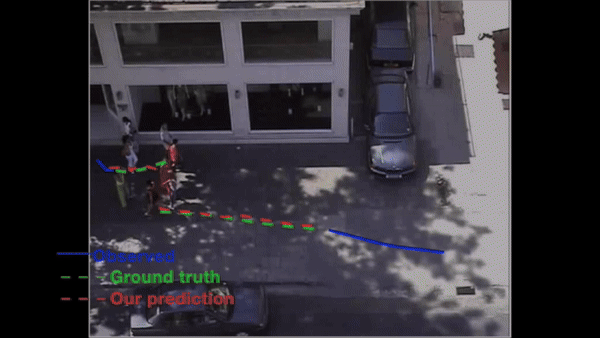
Human-centered computer vision focuses on developing AI systems that can understand, predict, and assist human behaviour in real-world environments. My research in this area has mainly explored pedestrian perception, including pedestrian trajectory prediction, crossing intention prediction, and pedestrian tracking. These studies aim to improve the ability of intelligent systems to understand people’s movements, intentions, and interactions with the surrounding environment, contributing to my broader goal of developing AI technologies that can assist humans and support safer, more intelligent real-world systems.
(1) Pedestrian Trajectory Prediction
(2) Pedestrian Crossing Intention Prediction

Related publications:
- X. Zhang*, P. Angeloudis, Y. Demiris. ST CrossingPose: A Spatial-Temporal Graph Convolutional Network for Skeleton-based Pedestrian Crossing Intention Prediction, IEEE Transactions on Intelligent Transportation Systems, vol. 23, no. 11, pp. 20773-20782, 2022.
- X. Zhang*, P. Angeloudis, Y. Demiris. Dual-branch Spatio-Temporal Graph Neural Networks for Pedestrian Trajectory Prediction, Pattern Recognition, vol. 142, 2023.
- X. Zhang*, Y. Demiris. Self-Supervised RGB-T Tracking with Cross-Input Consistency. arXiv preprint arXiv:2301.11274 (2023).
- J. Liu, P. Ye. X. Zhang*, G. Xiao. Real-time long-term tracking with reliability assessment and object recovery. IET Image Processing, vol. 15, no. 4, pp. 918-935, 2021.
- J. Liu, G. Xiao, X. Zhang*, P. Ye, X. Xiong, S. Peng. Anti-occlusion object tracking based on correlation filter. Signal, Image and Video Processing, vol. 14, no. 4, pp. 753-761, 2020.
- J. Zhao, G. Xiao*, X. Zhang*, D. P. Bavirisetti. An improved long-term correlation tracking method with occlusion handling. Chinese Optics Letters, vol. 17, no. 3, pp. 031001-1: 031001-6, 2019.
4. Trustworthy and Responsible AI
Trustworthy and responsible AI focuses on developing AI technologies that are reliable, robust, privacy-preserving, and socially responsible. My current work in this area includes privacy protection in visual data, with a particular focus on reducing the risk of exposing identifiable personal information while preserving the utility of images and videos for computer vision tasks.
Pedestrian Privacy Protection
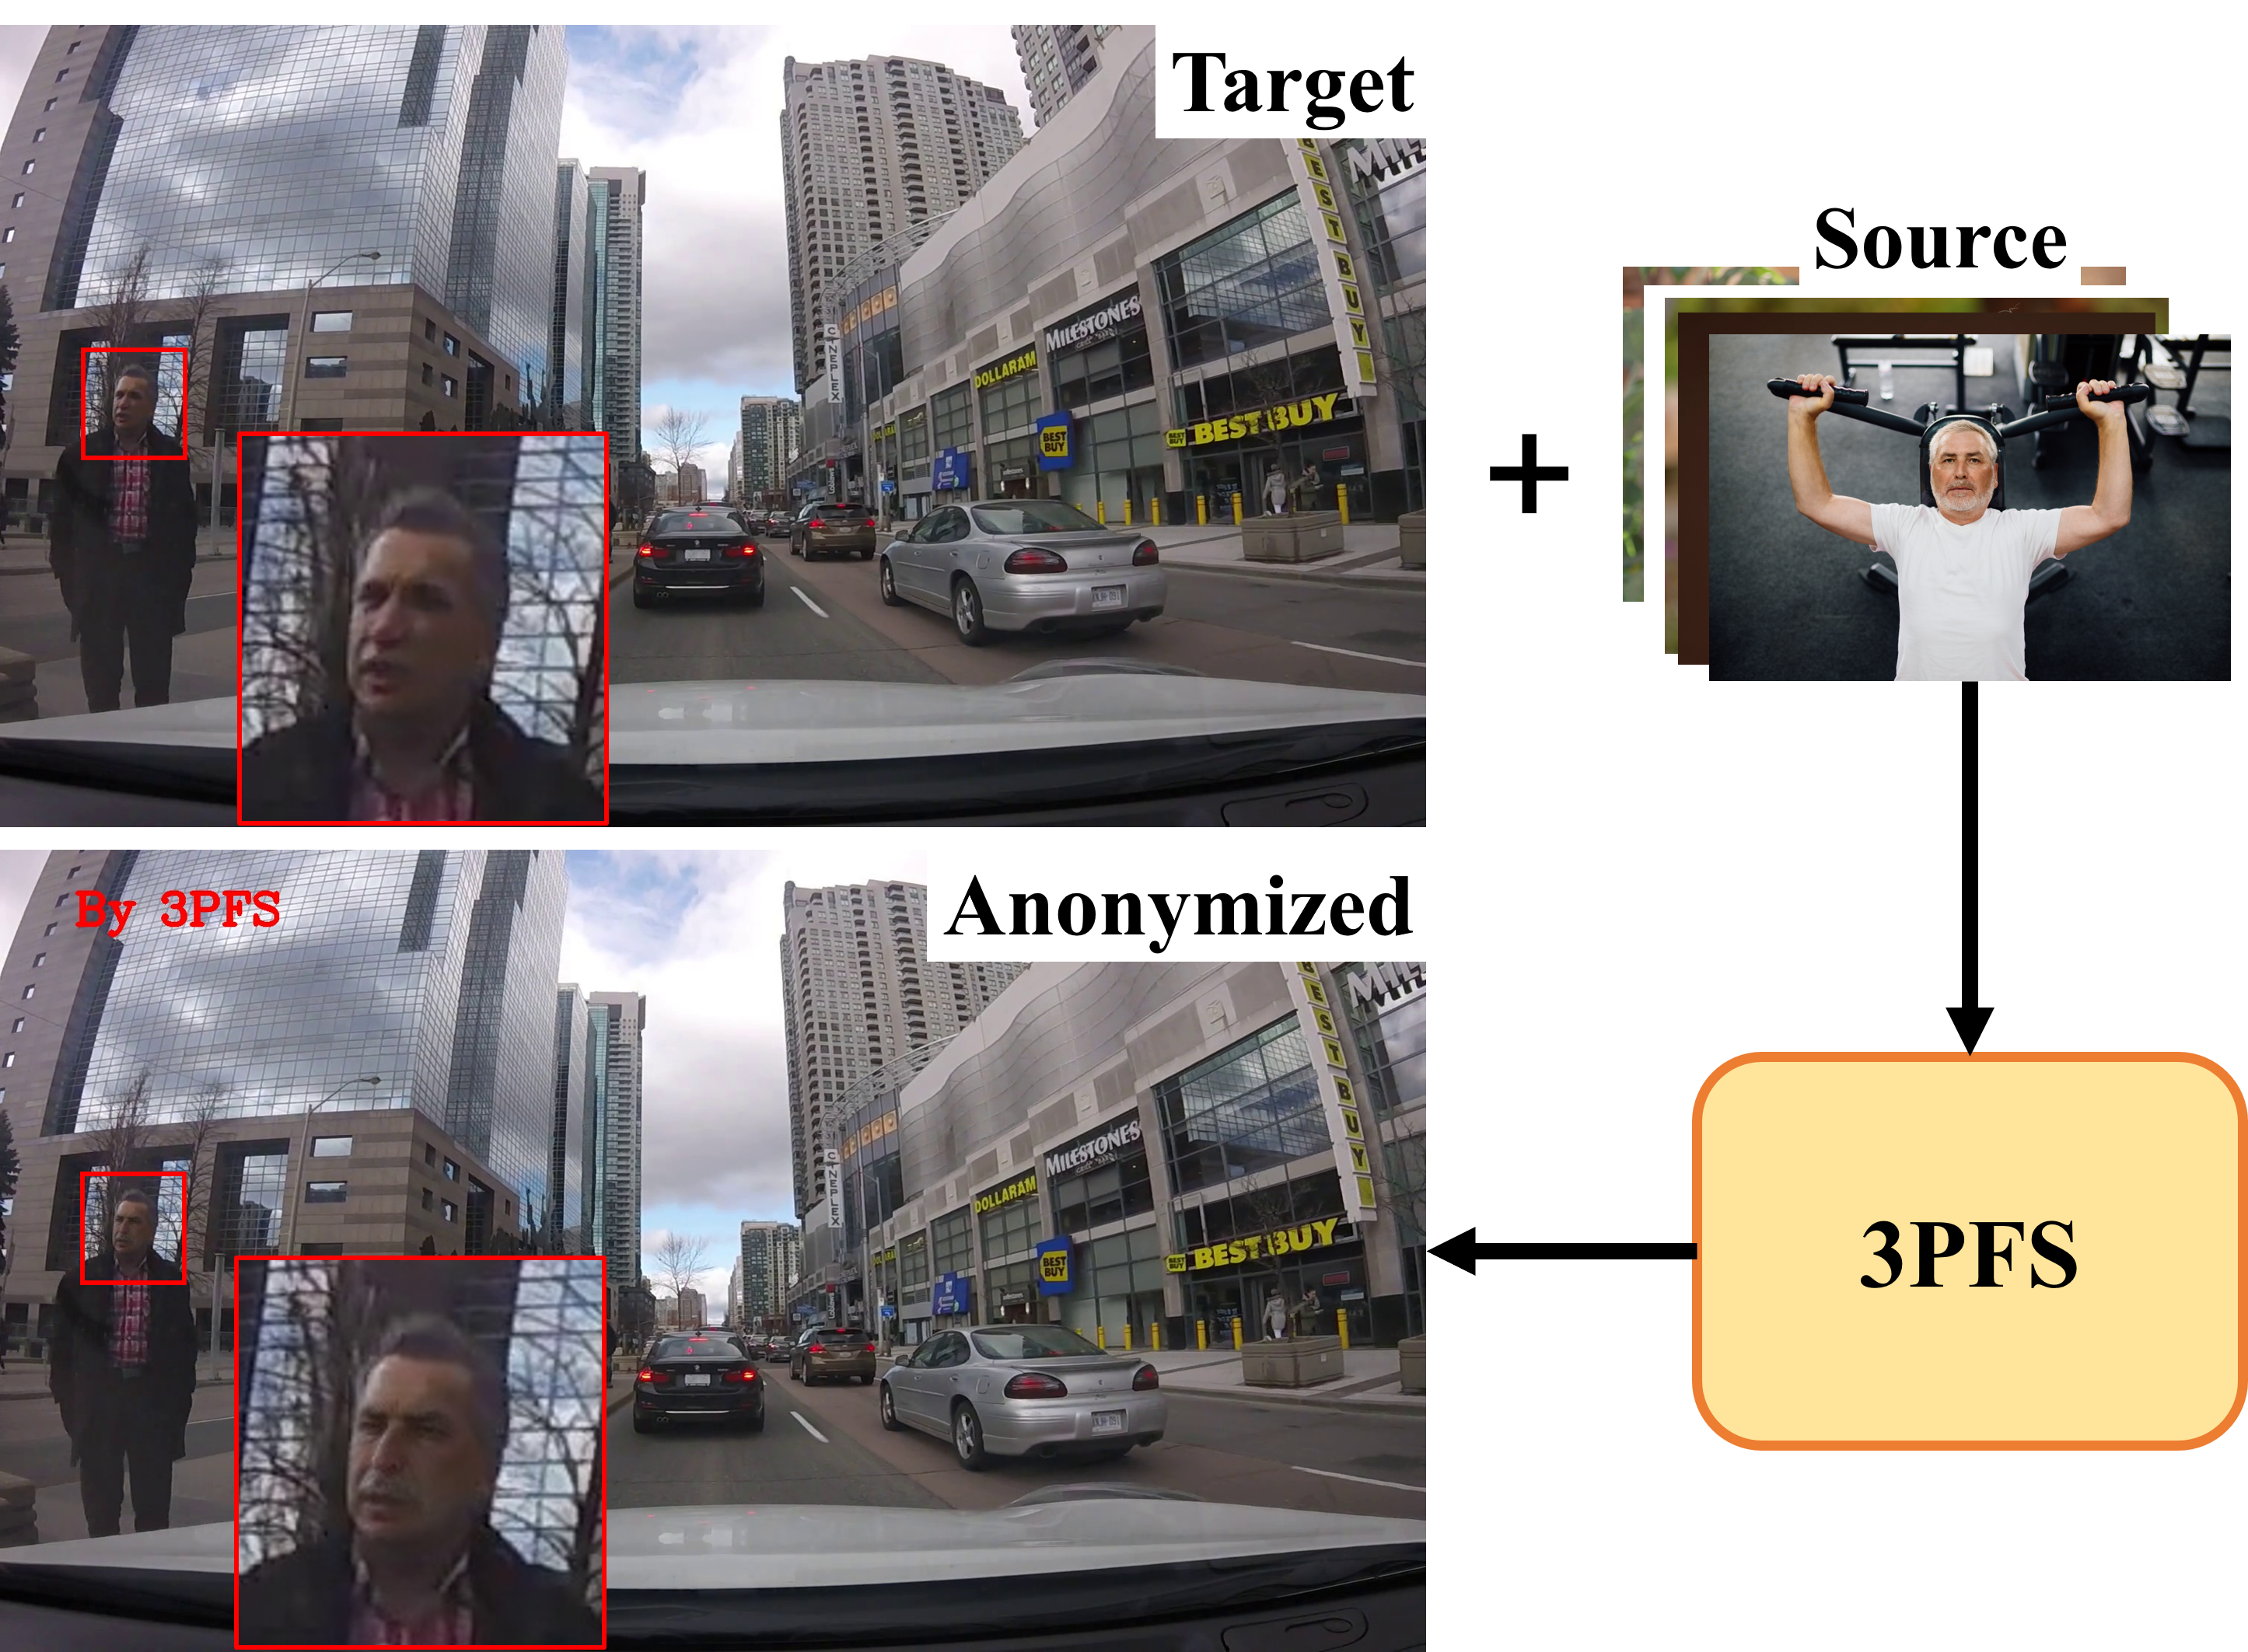
Many videos are captured to train AI models. We aim to protect pedestrian privacy in videos captured by cameras mounted on robots and vehicles while maintaining the utility of the anonymized videos. More details on our pedestrian privacy protection project can be found here.
Related publications:
- Z. Zhao, X. Zhang*, Y. Demiris. 3PFS: Protecting pedestrian privacy through face swapping, IEEE Transactions on Intelligent Transportation Systems, vol. 25, no. 11, pp. 16845-16854, 2024.
- X. Zhang*, Z. Zhao. More effort is needed to protect pedestrian privacy in the era of AI. NeurIPS Position Paper Track, 2025. Oral paper.
5. AI for Healthcare
AI for healthcare focuses on developing machine learning and computer vision methods for the analysis of medical images and biomedical multimodal data. My research in this area explores how AI can extract useful information from complex image-based and multimodal healthcare-related data. This direction builds on my broader interests in multimodal learning and image analysis.
Related publications:
- Q. Li, Z. Zhao, X. Zhang*. Brain tumor segmentation using multimodal MRI. BMVC Workshop 2025.